
The Inverted Conveyor Belt
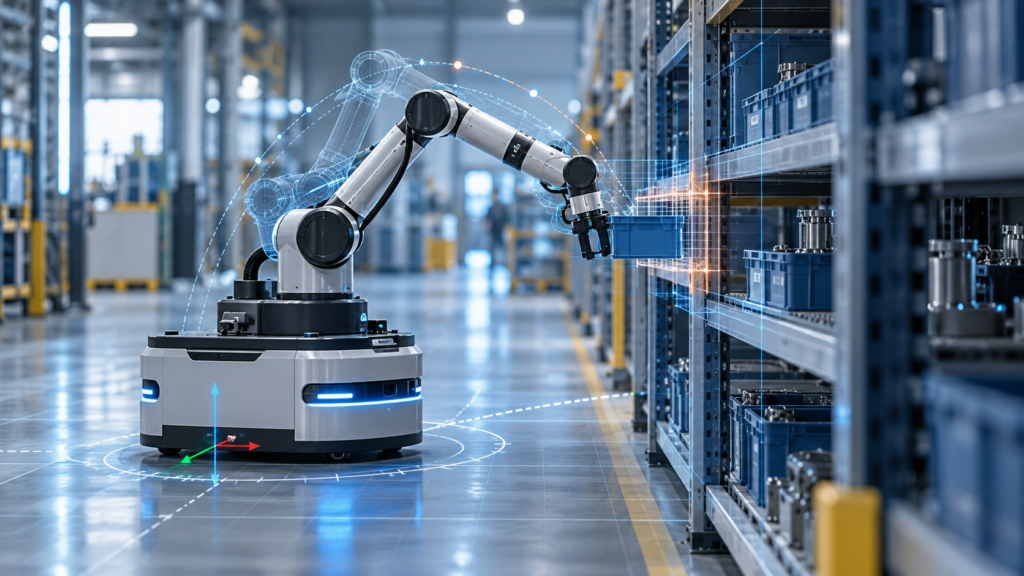
The Inverted Conveyor Belt What Mobile Manipulators Reveal About Scale Readiness Robotics is making impressive advances in manipulation. Vision-Language-Action models, learned control policies, and increasingly capable hardware are expanding what robots can accomplish beyond tightly controlled workcells. One development that interests me is the combination of robotic arms with mobile platforms, allowing machines to move […]
The System Doesn’t End at the Machine
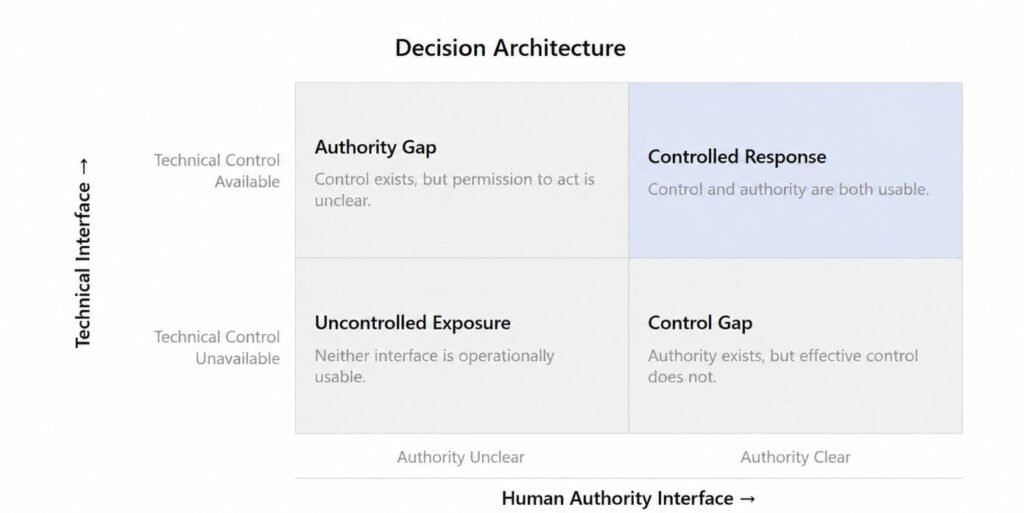
The System Doesn’t End at the Machine We often draw a robotic system’s boundary around the machine. We treat the hardware, software, sensors, controls, instruments, and interfaces as the system. We place the people who operate it, the procedures they follow, and the organization responsible for its use outside that boundary, and we label it […]
A Scale-Readiness View of the INMO Air3 Recall
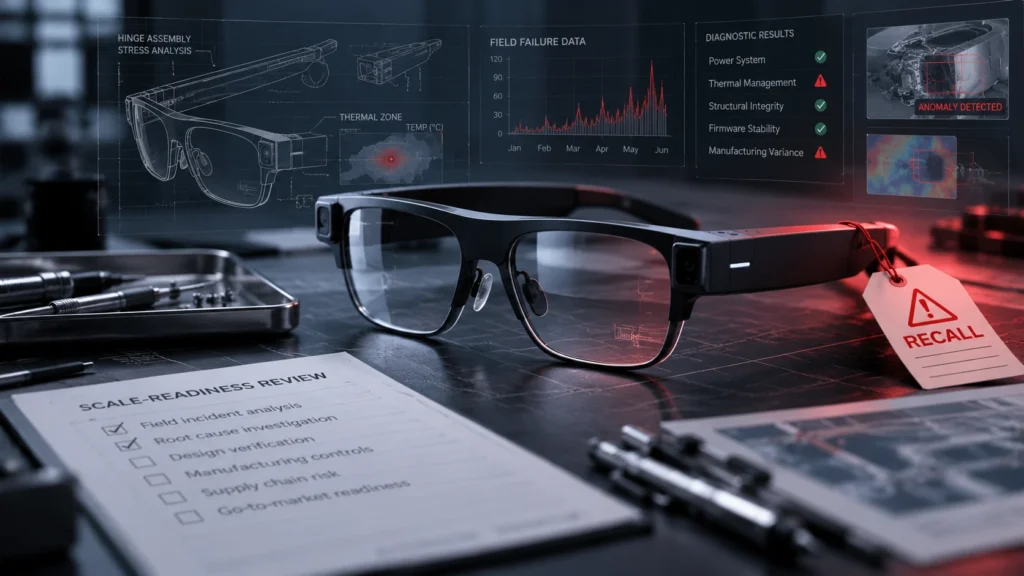
A Scale-Readiness View of the INMO Air3 Recall Extended Use Is a Different Test On September 24, the U.S. Consumer Product Safety Commission announced the recall of approximately 1,643 INMO Air3 smart glasses sold in the United States. According to the recall notice, the left temple can overheat during extended use, creating a burn hazard. […]
The Provenance of Evidence
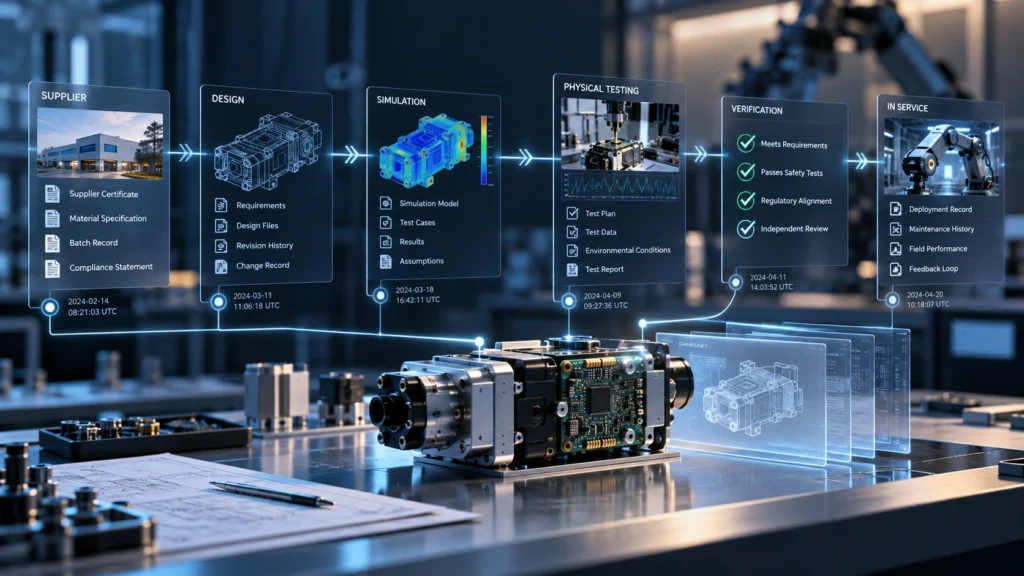
The Provenance of Evidence Why Pedigree Dictates Scale Readiness Scale-readiness evidence is becoming inseparable from provenance—the pedigree of components, models, data, simulations, suppliers, and regulatory claims. In robotics and advanced hardware, proof of function is not proof of scale. A prototype may work perfectly in a controlled environment, but as the system moves toward production, […]